Research at the Center for Digital Technology and Management 2018:
3D printing, Haptic Sensor Feedback, 3D Image Data
Obstacle avoidance for blind people:
 The product team presenting the prototype during the final presentation
During my time at the Center for Digital Technology and Management I was part of product development research project. In the world over 36 Million people are blind and struggle with navigation and obstacle avoidance every day. Therefore, the goal of the project was to use the depth information of a 3D camera to create an obstacle avoidance system for the blind. The developed solution consists of 3D printed frames including a depth camera, which is capturing the surroundings for the user. The input image is then processed, downscaled, and filtered to capture only the relevant information. Then the output can be transmitted to the user via a newly designed haptic feedback sleeve. The sleeve consists of an array of vibration motors, which can vary their vibration strength. This allows the recognition of the spatial location and size of obstacles surrounding the user and therefore enables easy indoor navigation without any visual input. The system was tested in a small study using an obstacle path and tracking the user adaption to the system over the period of 3 weeks. The results showed improvements in speed and ability to navigate to the goal destination. Therefore the developed system shows huge potential to enable easy indoor navigation and obstacle avoidance for blind people.
Download Paper: Obstacle avoidance for blind people using a 3D camera and a haptic feedback sleeve
Press articles:
- NewScientist (English)
- TheIndependent (English)
- Futurism NeoScope (English)
- InterestingEngineering (English)
- 3DPrintingIndustry.com (English)
- Comunidades Lusófonas (Portuguese)
- El Español (Spanish)
- Okdiario (Spanish)
- ZAP Notícias - AEIOU (Portuguese)
- Lenta.ru (Russian)
- Katun24 (Russian)
- MSN Wiadomości (Polish)
- Chip (Polish)
- NexTech (Slovak)
- Descopera.ro (Romanian)
- Webtekno (Turkish)
- SputnikNews (Turkish)
- Muhalif (Turkish)
- Netcost-Security (French)
- TrustMyScience (French)
- Olhar Digital (Portuguese)
- InSide (Chinese)
- Sohu (Chinese)
- Want (Dutch)
- ISNA (Persian)
- TechXplore (English)
- Vision-Systems.com (English)
- 3d-grenzenlos (German)
- Arover (English)
- BGR (English)
- FreeMalaysiaToday (English)
- cnBeta (Chinese)
- TechOffside.com (Thai)
- Crumpe (French)
- Dan Viet (Vietnamese)
- Teadus (Estonian)
- Positivr (French)
- Vanity Class (Italian)
- Ladepeche (French)
- Lenta (Russian)
- Connect (Romanian)
- Popmech (Russian)
- Vseosvita (Ukrainian)
- Hromadske (Ukrainian)
- Olhardigital (French)
- Coolblindtech (English)
- Propakistani (English)
- Wevolver (English)
- Altusintel (Egnlish)
- Copyfuture (English)
- Newstextarea (English)
- Sydneytoday (Chinese)
- Plugavel (English)
- Techunwrapped (English)
- Impactlab (English)
- Mywinet (English)
- Sondakika7 (English)
- Qnewscrunch (English)
- Thestar (English)
- Lire Le Monde (French)
- Noticias Moviles (Spanish)
- El Sie 7e (Spanish)
- Awoum (English)
- Cyfrowa (Polish)
- Elektronik Praxis (German)
- Framos.com (English)
 The 3D printed Glasses with depth capability, the haptic sleeve prototype and the depth image used as an input
Some of my other projects:
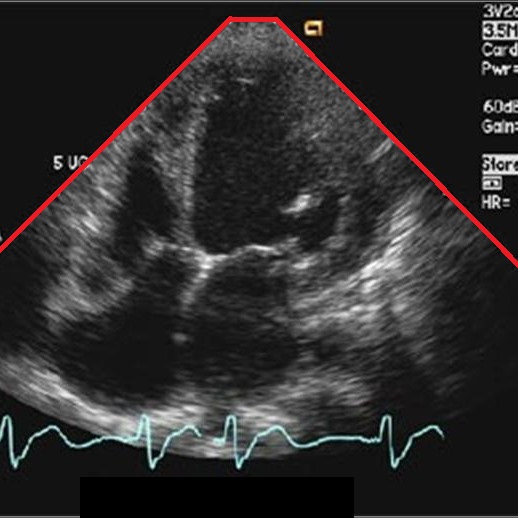
During my time as a researcher at the Biorobotics Lab of the Harvard University in Massachusetts, I use machine learning to develop a segmentation and classification of heart diseases based on ultrasonic images.
Learn More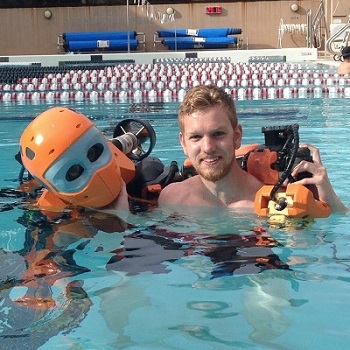
I was a researcher at the Robotics Lab of the Stanford University in California, working in the field of underwater Robotics. I developed an underwater hand gesture recognition for diver-robot interaction.
Learn More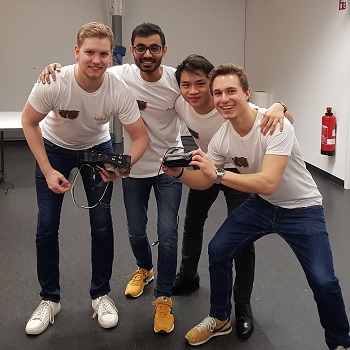
During my studies at the CDTM I was working on a technology consulting project to develop a prototype of 3D-enabled glasses and an haptic feedback wristband for enhanced navigation of blind people.
Learn More
During my electrical engineering studies I developed an automatic throwing robot concept, able to throw different balls to specific distances. My team won the second place at the "AdvEIsor" competition, being the only team to fulfill all technical tests.
Learn More